Cushion: Soft Robotics Simulation in Grasshopper, Powered by SOFA
2026
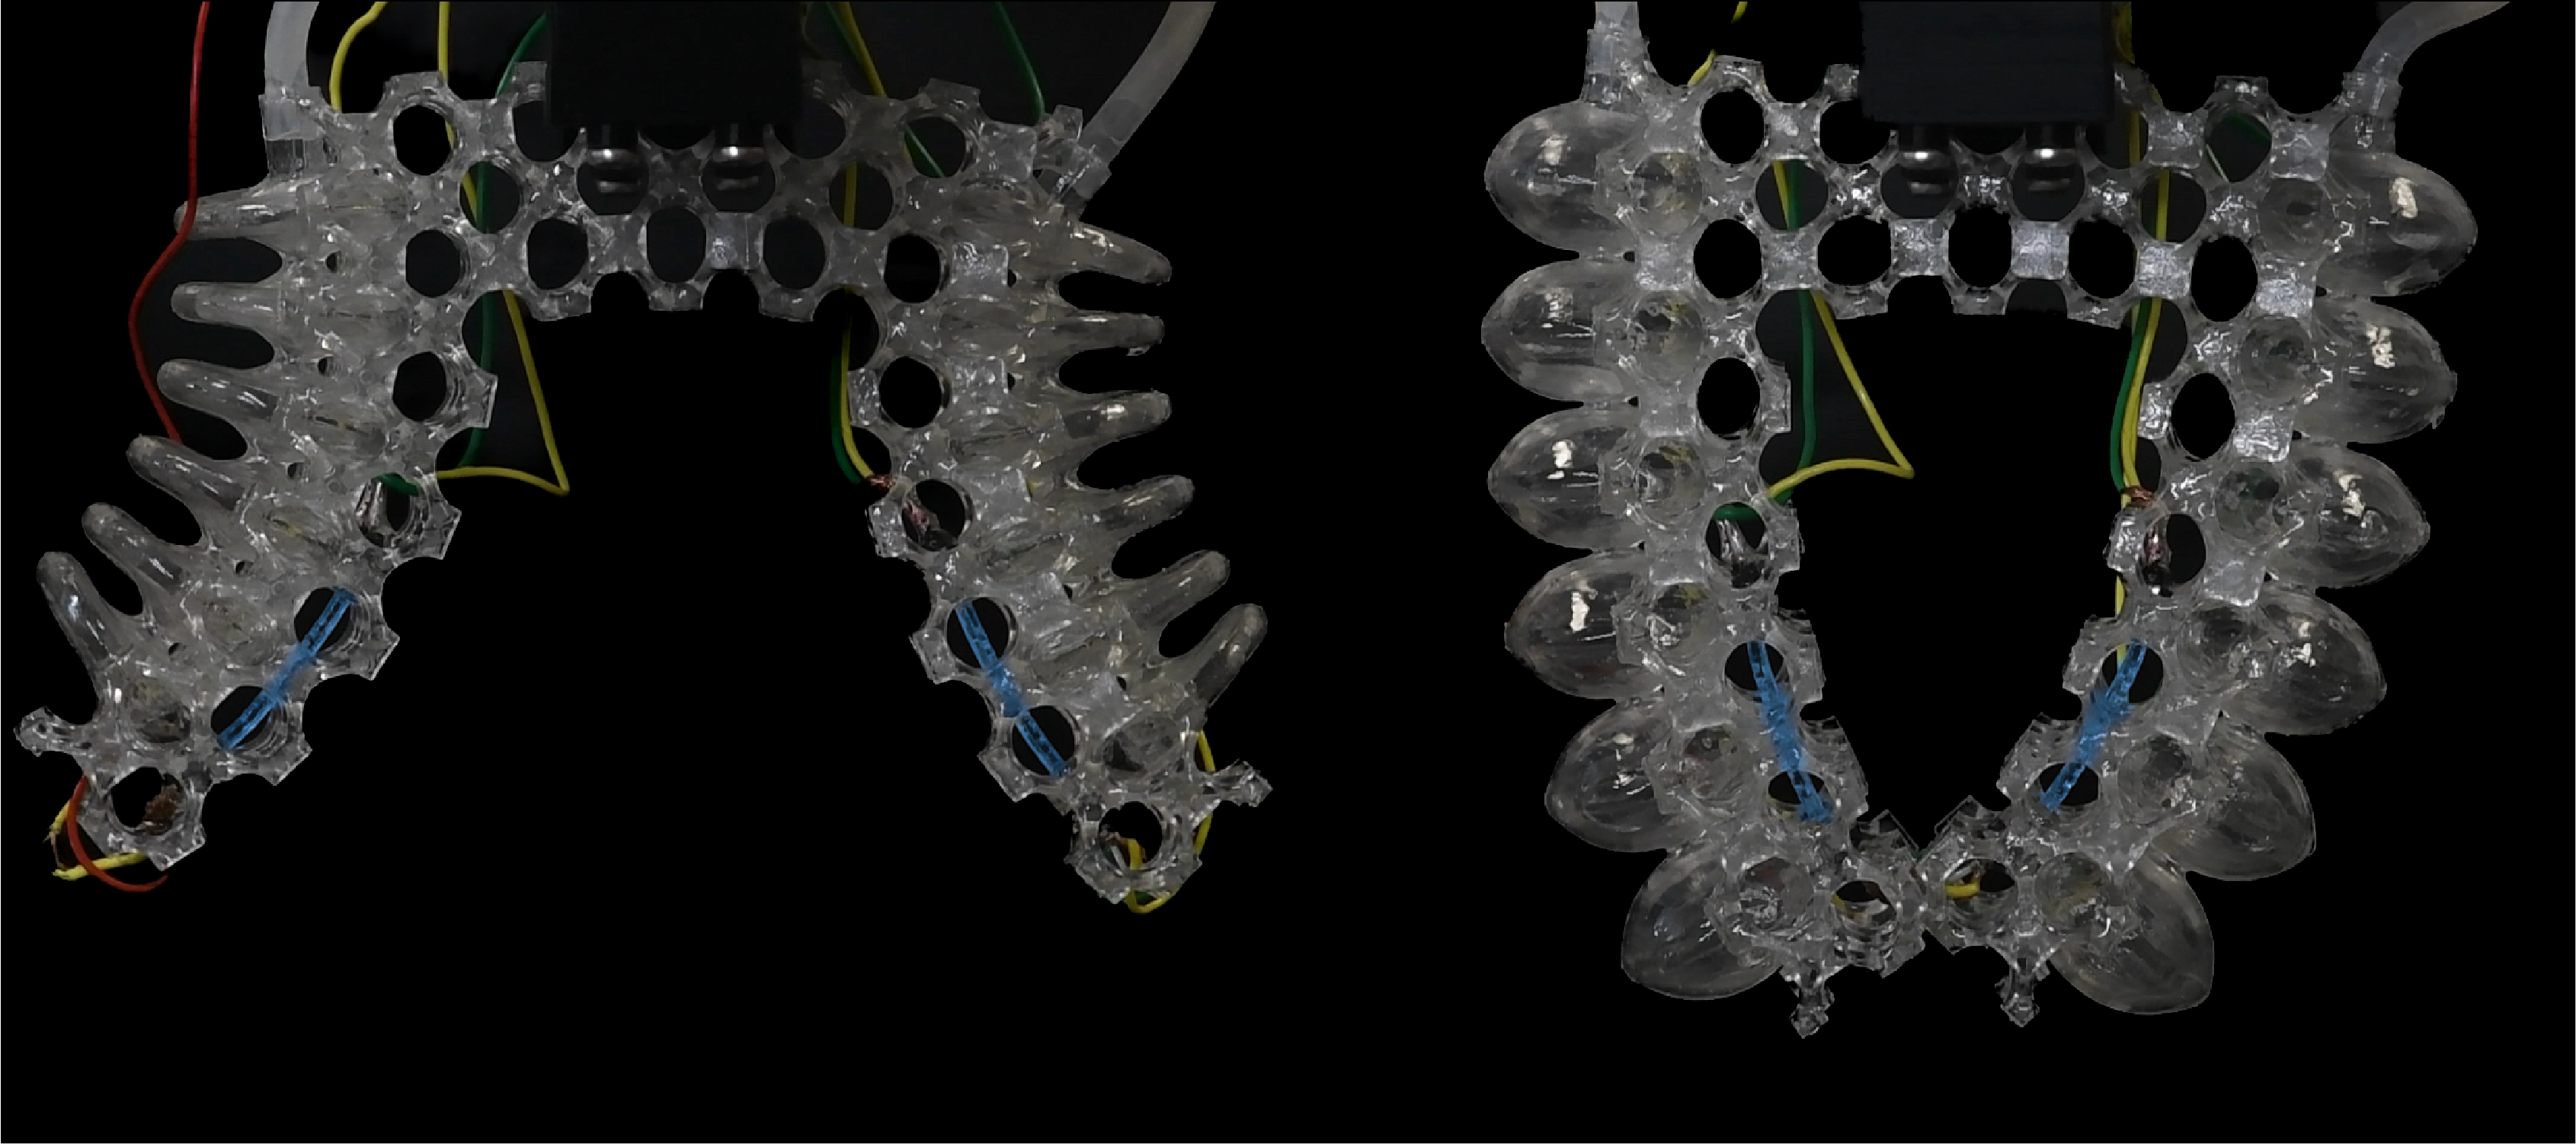
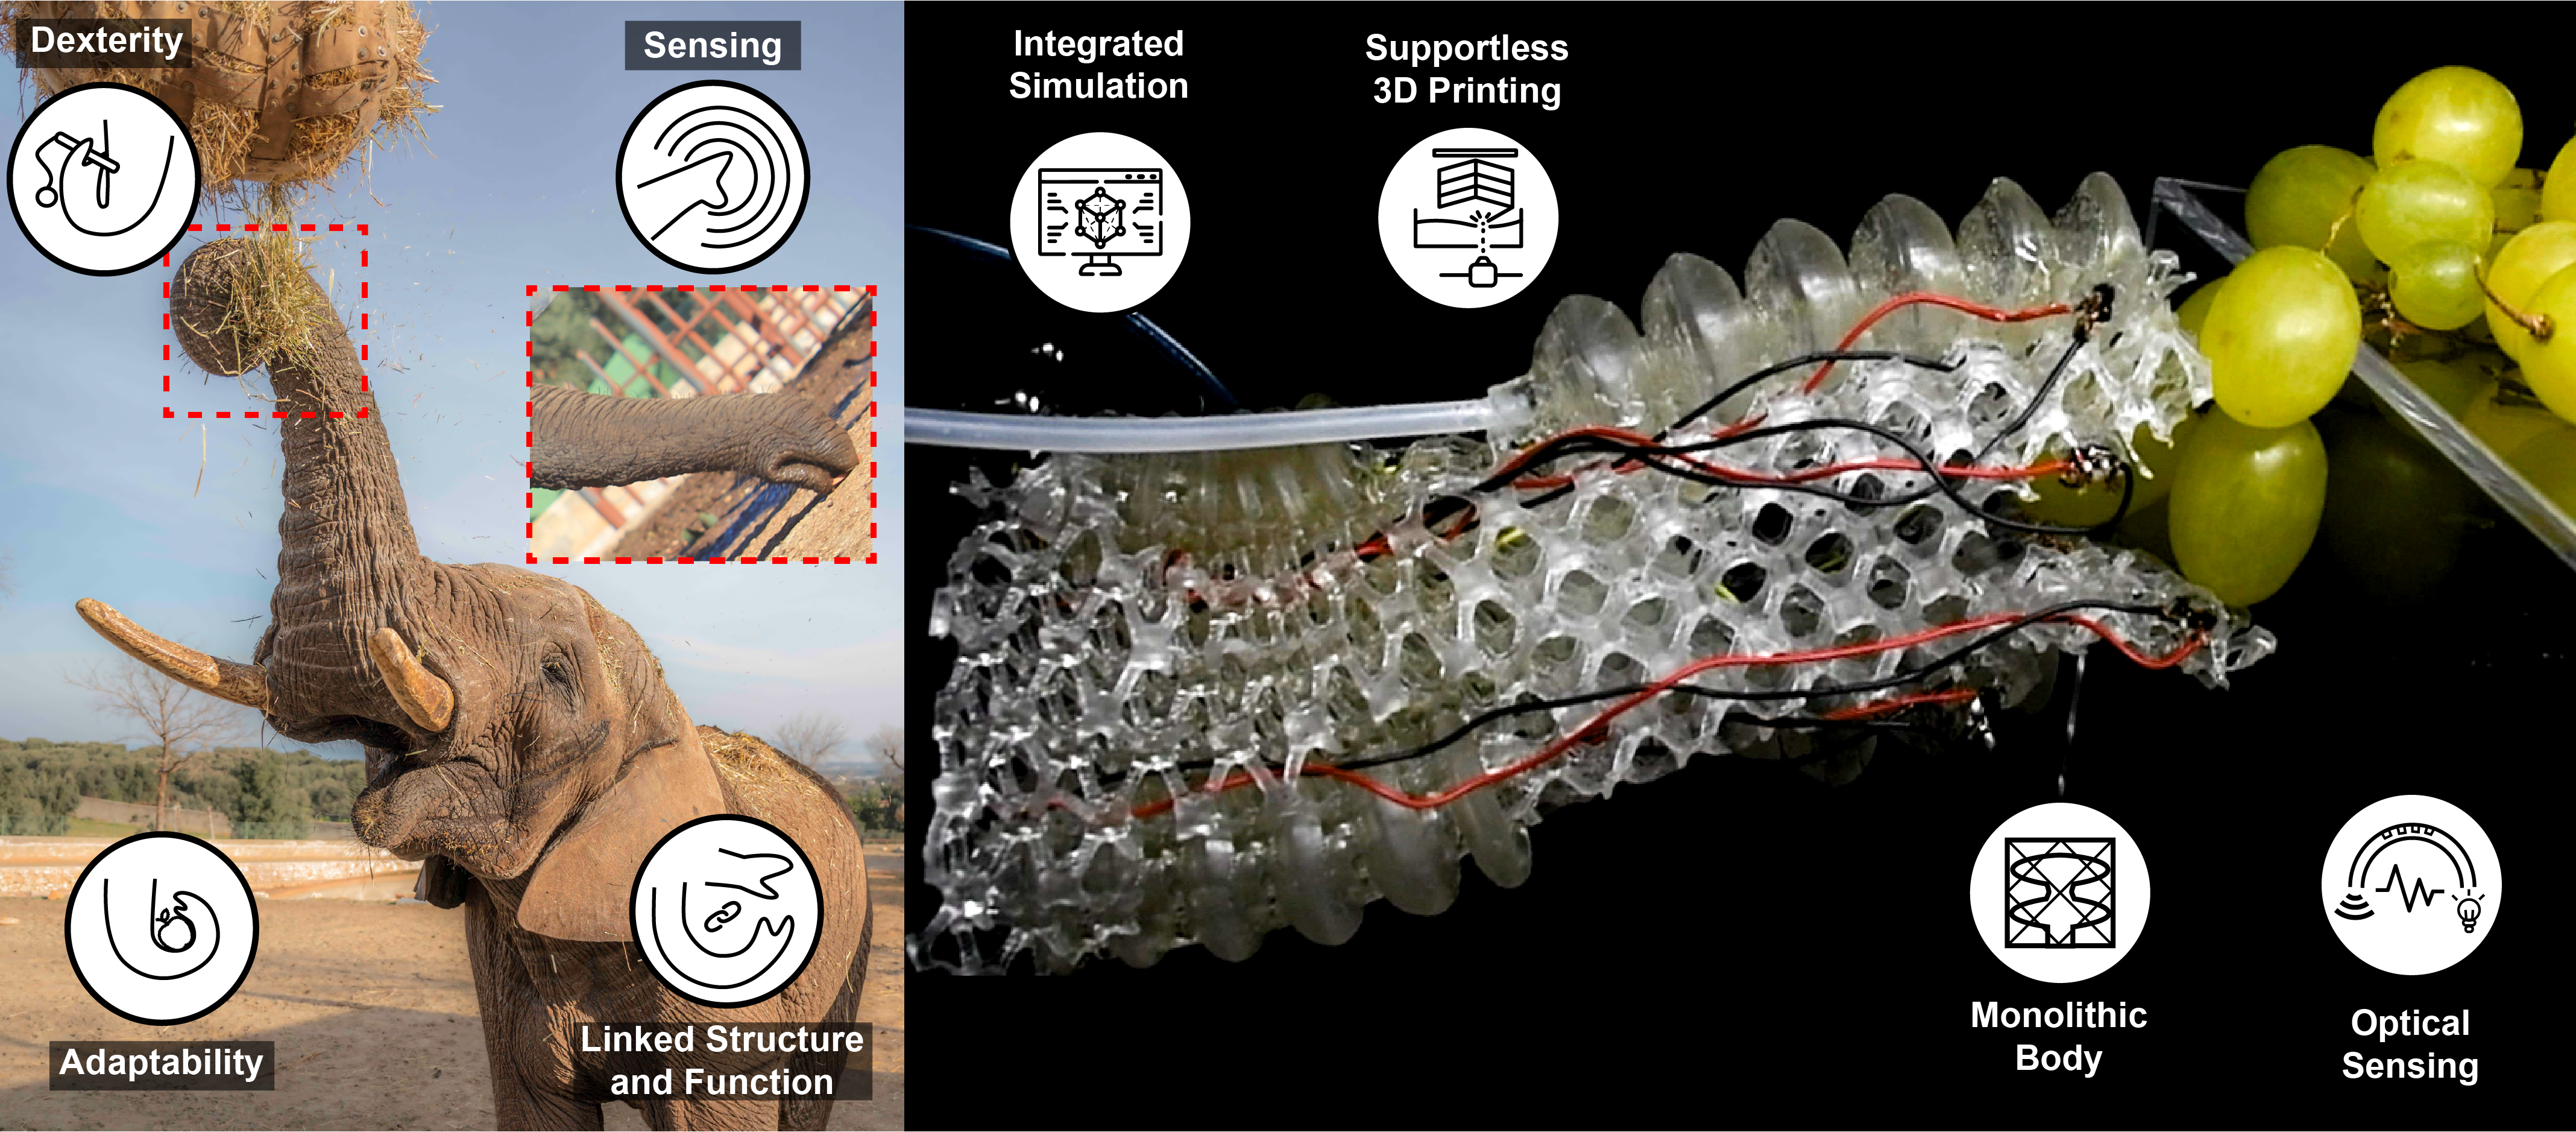
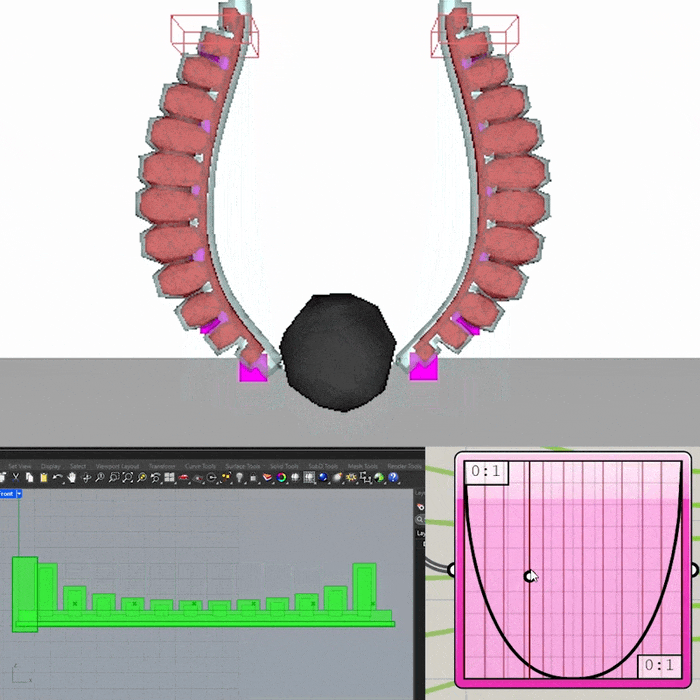
Open-source Grasshopper plugin that runs SOFA soft-body FEM directly from parametric models. Define a body, its cavities or tendons, and an actuation schedule, and get trajectories, forces, and deformed shapes back on the canvas.